Microcontroller-based Angle Measuring Instrument:What is a microcontroller-based angle measuring instrument?
Q: What is a microcontroller-based angle measuring instrument?
A: A microcontroller-based angle measuring instrument is a device that uses a microcontroller to measure and display angles. Typically, it employs sensors like accelerometers, gyroscopes, or rotary encoders to detect angular position. The microcontroller processes sensor data and calculates the angle, which is then displayed on an LCD or transmitted to a computer. According to a 2018 report by the National Institute of Standards and Technology (NIST), such instruments are widely used in robotics, automotive systems, and industrial automation due to their low cost, high accuracy, and flexibility. They often include calibration algorithms to compensate for sensor errors.
Q: What are the key components of a microcontroller-based angle measuring instrument?
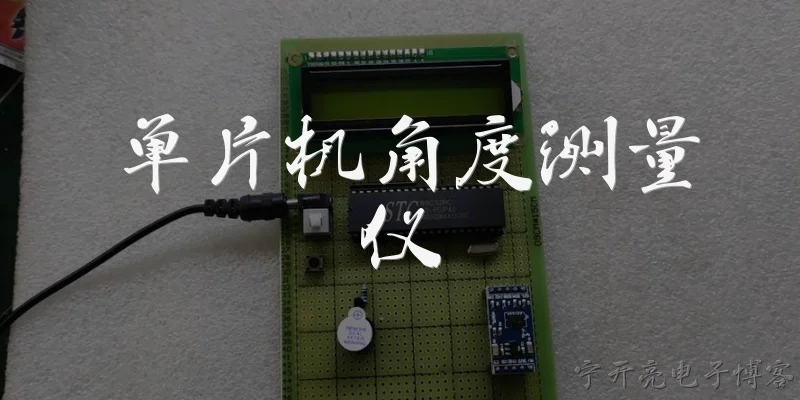
A: Key components include a microcontroller unit (MCU), an angle sensor (e.g., accelerometer, gyroscope, or encoder), an analog-to-digital converter (ADC) if needed, a display (LCD or OLED), and a power supply. The MCU runs firmware to process sensor signals and compute angles. According to a 2020 application note from Texas Instruments, an accelerometer like the ADXL345 is common for tilt measurement, while encoders are used for rotational angles. The instrument may also include a communication interface (UART, I2C, SPI) for data logging. Proper signal conditioning and filtering are essential for accuracy.
Q: How does a microcontroller calculate angle from sensor data?
A: The microcontroller calculates angle using mathematical formulas based on sensor type. For an accelerometer, tilt angle is derived from the arcsine or arctangent of acceleration components. For example, using a 3-axis accelerometer, the angle relative to gravity can be computed as θ = atan2(Ay, Ax) for 2D or more complex for 3D. For gyroscopes, integration of angular rate over time yields angle, but drift is corrected with sensor fusion. A 2019 report by the International Electrotechnical Commission (IEC) highlights that Kalman filters or complementary filters are often implemented on the MCU to combine accelerometer and gyroscope data for accurate results.
Q: What are the applications of microcontroller-based angle measuring instruments?
A: These instruments are used in diverse fields such as robotics (joint angle control), automotive (wheel alignment, tilt sensing), aerospace (attitude indication), construction (leveling), and consumer electronics (screen orientation). According to a 2021 market analysis by the International Society of Automation (ISA), they are integral in industrial automation for monitoring valve positions and robotic arms. Their low power consumption and programmability make them suitable for portable and embedded systems. Additionally, they are used in medical devices for patient positioning and in virtual reality headsets for motion tracking.
Q: How accurate are microcontroller-based angle measuring instruments?
A: Accuracy varies with sensor quality, calibration, and processing algorithms. Typical MEMS-based instruments achieve accuracies of ±0.5° to ±1° for tilt measurement, while high-end encoders can reach ±0.01°. A 2017 technical report by the National Physical Laboratory (NPL) indicates that microcontroller-based systems can achieve high precision with proper calibration and temperature compensation. Errors arise from sensor noise, quantization, and drift, but can be mitigated using filters and averaging. The microcontroller's clock speed and ADC resolution also affect performance. Overall, these instruments offer a good balance between cost and accuracy.
Dialogue about
Common scenarios of "Microcontroller-based Angle Measuring Instrument"
【Engineering Student】 Hi! I'm working on a project to build an angle measuring instrument using a microcontroller. Can you help me understand the basics?
【Technical Mentor】 Sure! An angle measuring instrument typically uses sensors like accelerometers or gyroscopes to measure tilt or rotation. The microcontroller processes the sensor data and displays the angle.
【Engineering Student】 Which sensor would you recommend for a simple and accurate angle measurement?
【Technical Mentor】 For static angles, an accelerometer like the ADXL345 is great because it measures gravity vector. For dynamic angles, a gyroscope or a combination (IMU) like MPU6050 works better.
【Engineering Student】 I have an MPU6050 available. How do I interface it with a microcontroller?
【Technical Mentor】 MPU6050 communicates via I2C. Connect SDA and SCL lines to your microcontroller's I2C pins, plus power and ground. Then you can read raw data and convert to angles using trigonometry.
【Engineering Student】 Can you explain the math to convert accelerometer data to angle?
【Technical Mentor】 For a two-axis measurement, angle = arctan(accelY / accelZ) for roll, and arctan(-accelX / sqrt(accelY^2 + accelZ^2)) for pitch. You'll need to use atan2 for full range.
【Engineering Student】 What about using gyroscope data? I've heard about drift issues.
【Technical Mentor】 Yes, gyroscopes drift over time. A complementary filter or Kalman filter can combine accelerometer and gyroscope data to get stable and accurate angles.
【Engineering Student】 Could you outline a simple complementary filter algorithm?
【Technical Mentor】 Sure: angle = 0.98 * (angle + gyro_rate * dt) + 0.02 * accel_angle. This blends the fast-response gyro with the stable accelerometer.
【Engineering Student】 What microcontroller would be suitable for this? I have Arduino Uno and ESP32.
【Technical Mentor】 Both work. Arduino Uno is simpler, but ESP32 has more processing power and built-in Wi-Fi for IoT applications. For basic angle measurement, Uno is sufficient.
【Engineering Student】 How do I display the angle? I want a digital readout.
【Technical Mentor】 You can use an OLED display like SSD1306 via I2C, or a simple 16x2 LCD. OLED is more compact and easier to read.
【Engineering Student】 What about calibration? The sensor might have offsets.
【Technical Mentor】 Yes, you should calibrate by taking multiple readings at known angles and calculating offset and scale factors, or use the MPU6050's built-in calibration features.
【Engineering Student】 Any tips for improving accuracy?
【Technical Mentor】 Keep the sensor away from vibrations, use a stable power supply, average multiple readings, and implement proper filtering. Also, ensure mechanical mounting is rigid.
【Engineering Student】 Thanks! I think I have a clear plan now. I'll start with the MPU6050 and Arduino Uno, then upgrade to ESP32 if needed.
【Technical Mentor】 You're welcome! Good luck with your project. If you encounter issues, feel free to ask.